
Datasets:

Languages:
English
Size:
100K<n<1M
Tags:
autonomous-navigation
autonomous-driving
imitation-learning
continual-learning
domain-shift
semantic-segmentation
License:
checo1092 commited on
Commit ·
0f9d1cd
1
Parent(s): f0fc049
Add dataset visualization preview
Browse files- .gitattributes +1 -0
- README.md +15 -2
- docs/assets/viewer.png +3 -0
.gitattributes
CHANGED
|
@@ -1,4 +1,5 @@
|
|
| 1 |
*.tar filter=lfs diff=lfs merge=lfs -text
|
|
|
|
| 2 |
*.md text
|
| 3 |
*.json text
|
| 4 |
*.csv text
|
|
|
|
| 1 |
*.tar filter=lfs diff=lfs merge=lfs -text
|
| 2 |
+
*.png filter=lfs diff=lfs merge=lfs -text
|
| 3 |
*.md text
|
| 4 |
*.json text
|
| 5 |
*.csv text
|
README.md
CHANGED
|
@@ -190,16 +190,29 @@ LICENSE Dataset license statement.
|
|
| 190 |
|
| 191 |
## Dataset Viewer
|
| 192 |
|
| 193 |
-
The Hugging Face Dataset Viewer is disabled for this release
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
| 194 |
|
| 195 |
## Citation
|
| 196 |
|
| 197 |
Please cite the dataset DOI after it is minted for the frozen `v1.0.0` release. Until then, cite this repository and version explicitly.
|
| 198 |
|
| 199 |
```text
|
| 200 |
-
Sergio Delgadillo
|
| 201 |
```
|
| 202 |
|
|
|
|
|
|
|
| 203 |
## Limitations
|
| 204 |
|
| 205 |
EgoSpatial-CL is a simulated dataset. It does not provide continuous intra-sequence domain transitions, optical flow, dense depth, 2D/3D object boxes, or multi-view camera annotations. It should be used as a compact, spatially controlled dataset for navigation/control-oriented studies rather than as a replacement for large-scale perception datasets.
|
|
|
|
| 190 |
|
| 191 |
## Dataset Viewer
|
| 192 |
|
| 193 |
+
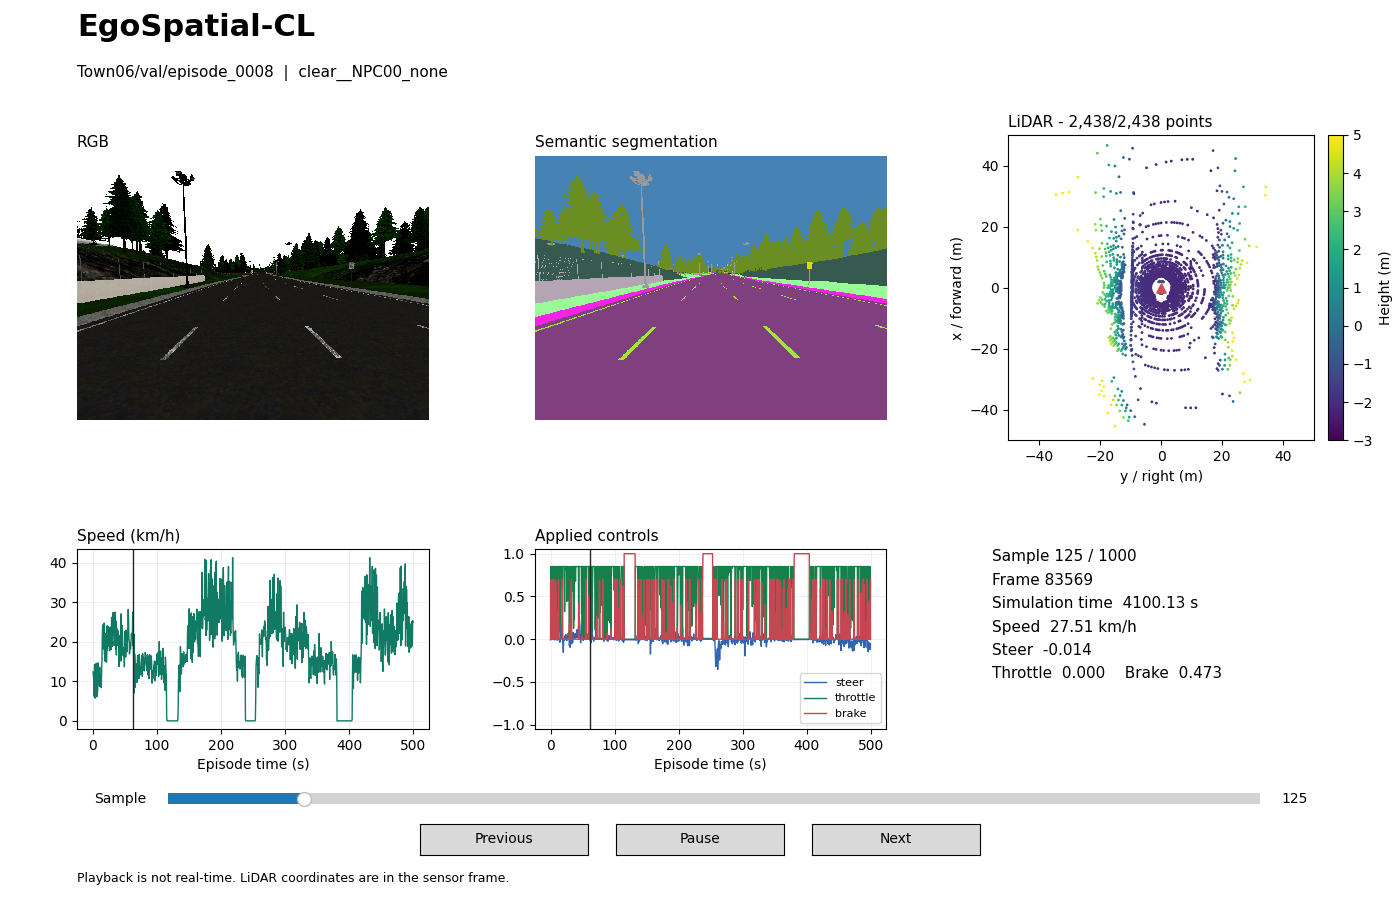
The Hugging Face Dataset Viewer is disabled for this release because the dataset
|
| 194 |
+
is distributed as complete episode tar shards rather than a WebDataset-native
|
| 195 |
+
sample layout. The release was not repacked solely for viewer compatibility,
|
| 196 |
+
which would require rewriting approximately 299 GB of packed data.
|
| 197 |
+
|
| 198 |
+
The accompanying code repository provides a
|
| 199 |
+
[local visualization tool](https://github.com/checo1092/egospatial-cl-code/blob/main/docs/visualization.md)
|
| 200 |
+
for synchronized RGB, semantic-segmentation, LiDAR, and vehicle-state samples.
|
| 201 |
+
|
| 202 |
+

|
| 203 |
+
|
| 204 |
+
Example: `Town06/val/episode_0008`, frame `83569`.
|
| 205 |
|
| 206 |
## Citation
|
| 207 |
|
| 208 |
Please cite the dataset DOI after it is minted for the frozen `v1.0.0` release. Until then, cite this repository and version explicitly.
|
| 209 |
|
| 210 |
```text
|
| 211 |
+
Sergio Delgadillo Marín, Juan Humberto Sossa Azuela, and Erik Zamora Gómez. EgoSpatial-CL: A Spatially Controlled Multimodal Dataset for Continual Learning in Simulated Autonomous Navigation. Version 1.0.0. Hugging Face dataset repository: https://huggingface.co/datasets/checo1092/egospatial-cl
|
| 212 |
```
|
| 213 |
|
| 214 |
+
All authors contributed equally to this work.
|
| 215 |
+
|
| 216 |
## Limitations
|
| 217 |
|
| 218 |
EgoSpatial-CL is a simulated dataset. It does not provide continuous intra-sequence domain transitions, optical flow, dense depth, 2D/3D object boxes, or multi-view camera annotations. It should be used as a compact, spatially controlled dataset for navigation/control-oriented studies rather than as a replacement for large-scale perception datasets.
|
docs/assets/viewer.png
ADDED
|
Git LFS Details
|