

AutoDex: An Automated Real-World System for Dexterous Grasping Data Collection
Paper • 2606.23689 • Published
Error code: JobManagerCrashedError
Need help to make the dataset viewer work? Make sure to review how to configure the dataset viewer, and open a discussion for direct support.
Autonomously building reusable grasp knowledge through real-world trials.
CoRL 2026
Project · Paper · Interactive Gallery · Code
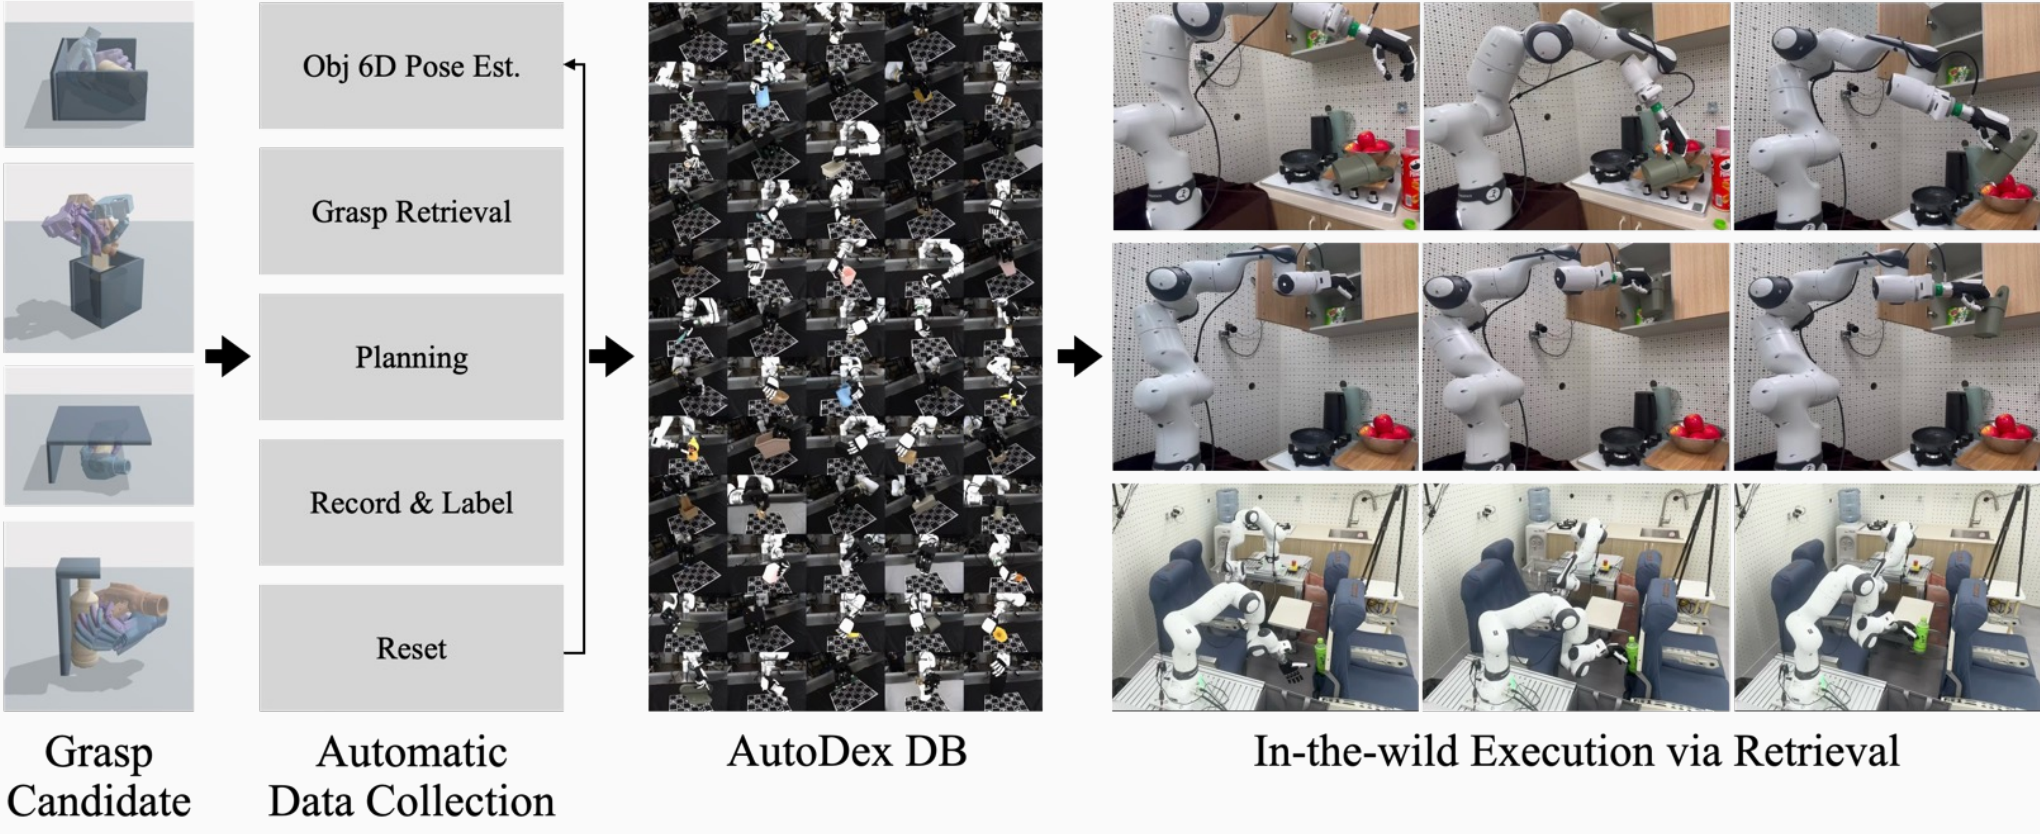
AutoDex lets a robot try grasps, verify outcomes, and reset objects autonomously—turning real-world experience into a reusable dexterous grasp library. Browse recorded trials in the interactive gallery, or download grasp annotations, robot trajectories, and multi-view recordings for your own experiments.
This release contains 2,610 real-robot grasp trials with Allegro and Inspire hands, with synchronized multi-view video, calibrated cameras, 6-DoF object poses, and executed grasp annotations.
| Subset | Robot | Trials |
|---|---|---|
allegro |
xArm6 + Allegro (16-DoF) | 2,226 |
inspire |
xArm6 + Inspire (6-DoF) | 384 |
| Data | Contents |
|---|---|
| Executed grasps | Wrist poses in the object frame and hand joint configurations |
| Robot motion | Arm and hand trajectories |
| Multi-view observations | Camera videos, intrinsics, and extrinsics |
| Object geometry in the scene | Object poses and, where available, tracked object trajectories |
| Trial metadata | Grasp timing, execution stages, and success annotations |
| Interactive previews | Animated 3D assets, thumbnails, and gallery videos |
Executed wrist poses are expressed in the object frame, allowing grasps to be reused relative to the object.
Install the download client:
pip install -U huggingface_hub numpy
Download the Allegro trials for one object:
from huggingface_hub import snapshot_download

snapshot_download(
    repo_id="willi19/autodex-gallery",
    repo_type="dataset",
    local_dir="autodex",
    allow_patterns=["allegro/attached_container/*"],
)
To download both hand subsets, replace allow_patterns with:
allow_patterns=["allegro/*", "inspire/*"]
These patterns select the trial data without downloading the separate gallery asset folders.
Compressed MP4 videos used by the interactive gallery are hosted in the companion autodex-gallery-video repository. Download the corresponding object with:
snapshot_download(
    repo_id="willi19/autodex-gallery-video",
    repo_type="dataset",
    local_dir="autodex-videos",
    allow_patterns=["allegro/attached_container/*"],
)
Trial data is organized by hand, object, and recording timestamp:
{hand}/{object}/{timestamp}/
├── pose_world.npy          # Object-to-world transform
├── R2C.npy                 # Robot-base-to-world transform
├── cam_param/              # Camera intrinsics and extrinsics
├── videos/                 # Camera recordings
├── arm/                    # Arm trajectories
├── hand/                   # Hand trajectories
├── executed_grasp/
│   ├── wrist_se3.npy       # Wrist pose in the object frame
│   ├── grasp_pose.npy      # Hand configuration at grasp
│   └── meta.json           # Timing, execution stages, and annotations
├── object_tracking/       # Object tracking outputs, where available
└── recompute_pose.json    # Pose-quality metadata
Additional top-level folders (interactive_3d/, turntable/, view_thumbnails/, experiments/, and experiments_proxy/) support the gallery. Available files and annotations can vary between trials.
import json
from pathlib import Path

import numpy as np

trial = Path("autodex/allegro/attached_container/20260121_163413")

object_to_world = np.load(trial / "pose_world.npy")
robot_to_world = np.load(trial / "R2C.npy")
wrist_in_object = np.load(trial / "executed_grasp/wrist_se3.npy")
finger_joints = np.load(trial / "executed_grasp/grasp_pose.npy")
with (trial / "executed_grasp/meta.json").open() as f:
    metadata = json.load(f)

# Transform the recorded wrist pose into the robot-base frame.
wrist_in_robot = np.linalg.inv(robot_to_world) @ object_to_world @ wrist_in_object

print("Hand configuration:", finger_joints)
print("Trial metadata:", metadata)
The transforms above are 4×4 homogeneous matrices. For a new placement, use the object's current pose and the calibration for your setup rather than the recorded scene pose.
@misc{choi2026autodex,
  title = {AutoDex: An Automated Real-World System for Dexterous Grasping Data Collection},
  author = {Choi, Mingi and Kim, Gunhee and Kim, Jisoo and Kim, Taeksoo and
            Ha, Taeyun and Lim, Jongbin and Joo, Hanbyul},
  year = {2026},
  eprint = {2606.23689},
  archivePrefix = {arXiv},
  primaryClass = {cs.RO}
}
Mingi Choi, Gunhee Kim, Jisoo Kim, Taeksoo Kim, Taeyun Ha, Jongbin Lim, and Hanbyul Joo · SNU and RLWRLD
For questions about the data, open a discussion on this dataset repository or contact [email protected].